
Hexapod Robot
Z@zeroshot18-servo hexapod on a printed hexagonal body; every part as editable parametric CAD, with the ripple-gait sketch.
The AI-powered studio that takes you from schematic to motion. Electronics, mechanics, simulation and motion design in one place.
Learn moreDescribe a project in your own words. The agent will set up your workspace and get started.
Real robots built in FloMotion. Open one to see how it works, or fork it and make it yours.
18-servo hexapod on a printed hexagonal body; every part as editable parametric CAD, with the ripple-gait sketch.

James Bruton's five-servo bipedal walker: four-bar printed legs, a weighted turning torso, ESP32 and a BNO08x IMU.

 @robot-learning-co
A 6-DOF follower arm on DAMIAO quasi-direct-drive motors with a rack-and-pinion gripper and wrist camera, teleoperated by a passive Dynamixel leader arm and LeRobot-native.

 @enactic
Two 7-DOF arms with pinch grippers and in-hand cameras on an aluminium pedestal, built on DAMIAO CAN-FD motors for teleoperation, data collection and robot learning. Open hardware from Enactic.

 @therobotstudio
A 3D-printed 6-DOF follower arm on six Feetech STS3215 serial bus servos, teleoperated by a matching leader arm to collect data and train AI policies with Hugging Face LeRobot.

 @alexanderkoch-koch
Alexander Koch's open-source 3D-printed robot arm for robot learning: two Dynamixel XL430s and four XL330s, about $250 for the follower, teleoperated by a matching leader arm.

 @jlmcreative
Un robot de seis patas hecho con paletas de helado, una pila 18650 y un solo motorreductor: una manivela mueve todas las patas.

A hopping Luxo Jr. desk lamp on five Savox servos, a Raspberry Pi 4 and a camera in the bulb; every printed part as editable parametric CAD.
@therobotstudioA 3D-printed 6-DOF follower arm on six Feetech STS3215 serial bus servos, teleoperated by a matching leader arm to collect data and train AI policies with Hugging Face LeRobot.
@enacticTwo 7-DOF arms with pinch grippers and in-hand cameras on an aluminium pedestal, built on DAMIAO CAN-FD motors for teleoperation, data collection and robot learning. Open hardware from Enactic.
@alexanderkoch-kochAlexander Koch's open-source 3D-printed robot arm for robot learning: two Dynamixel XL430s and four XL330s, about $250 for the follower, teleoperated by a matching leader arm.
@robot-learning-coA 6-DOF follower arm on DAMIAO quasi-direct-drive motors with a rack-and-pinion gripper and wrist camera, teleoperated by a passive Dynamixel leader arm and LeRobot-native.
@jlmcreativeUn robot de seis patas hecho con paletas de helado, una pila 18650 y un solo motorreductor: una manivela mueve todas las patas.

Open-source 6-axis 3D-printed robotic arm on NEMA17 steppers with printed gears and GT2 belts; 625 mm reach, 750 g payload, G-code and ROS 2 control.
A hopping Luxo Jr. desk lamp on five Savox servos, a Raspberry Pi 4 and a camera in the bulb; every printed part as editable parametric CAD.
James Bruton's five-servo bipedal walker: four-bar printed legs, a weighted turning torso, ESP32 and a BNO08x IMU.
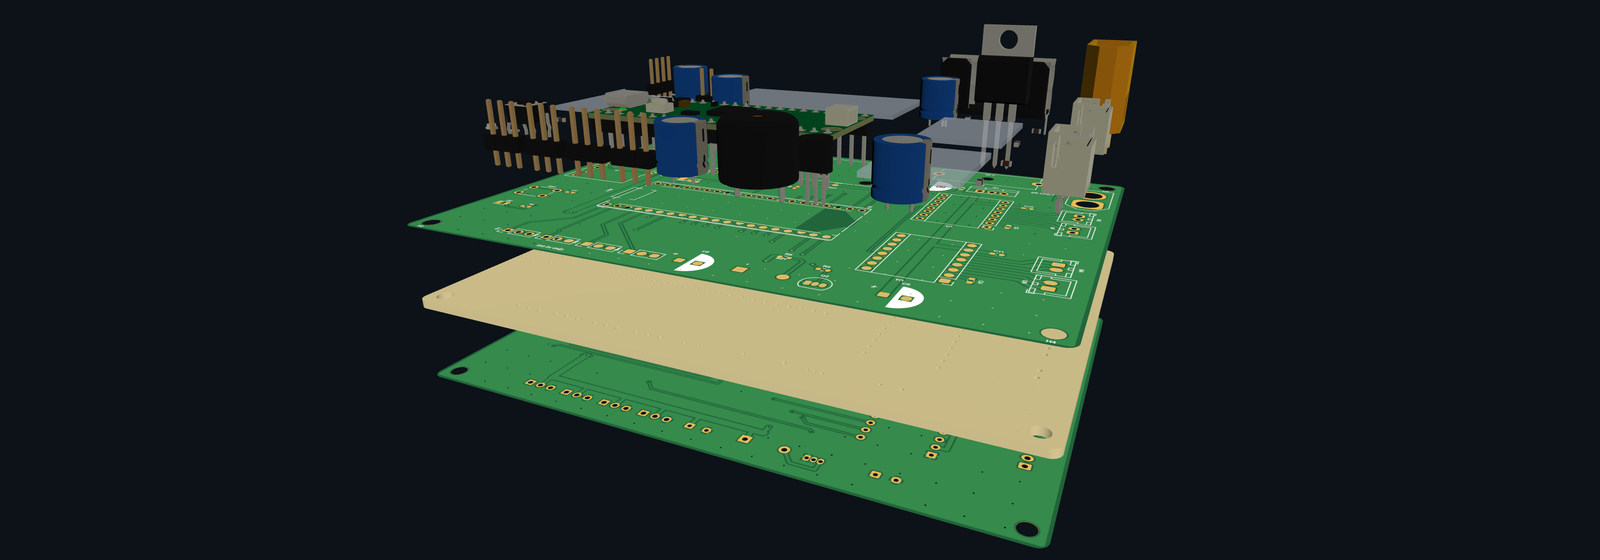
Turn a schematic into a KiCad 10 printed circuit board in the browser. Place parts, route tracks, fill copper pours, run design rule checks, view the board in 3D and prepare JLCPCB assembly files by hand or with an AI agent.
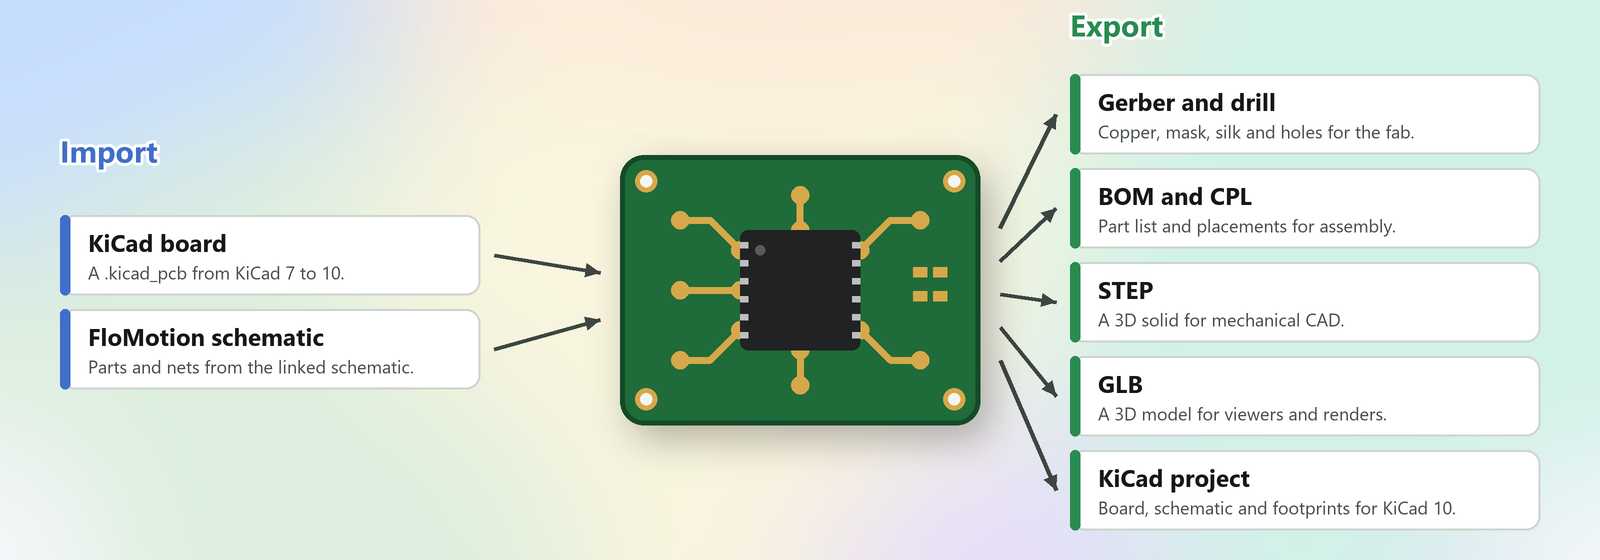
Exporting Gerber, drill, BOM, CPL, STEP, GLB and KiCad project files from a PCB layout, and loading KiCad boards back into FloMotion.
Wings, propellers and hulls are judged by the forces a moving fluid exerts on them: lift, drag, thrust and torque. Historically measured in wind tunnels, these forces are also computed numerically on a mesh of cells around the shape. This article explains the numbers behind wing and propeller tests, and follows a glider wing, a drone propeller and a model boat hull through a flow simulation on a FloMotion test bench.
Share what you're building, get help, and follow along as we ship new features.